Move
Transport people, payloads, and modules between operating locations.
Swarm Index · Transportation
Modular transportation architectures for people, payloads, and technical systems across changing environments and mission phases.
Operational objective
Swarm Spatial develops physical, control, and intelligent architectures that connect movement, load transfer, and reconfiguration across different operating conditions.
Transport people, payloads, and modules between operating locations.
Adapt configurations to terrain, load, and mission phase.
Coordinate mobility, navigation, and distributed systems as one operation.
System architectures
The lead technology gives this field a clear centre of gravity. Supporting architectures connect the functions relevant to its operational objective.
Featured technology
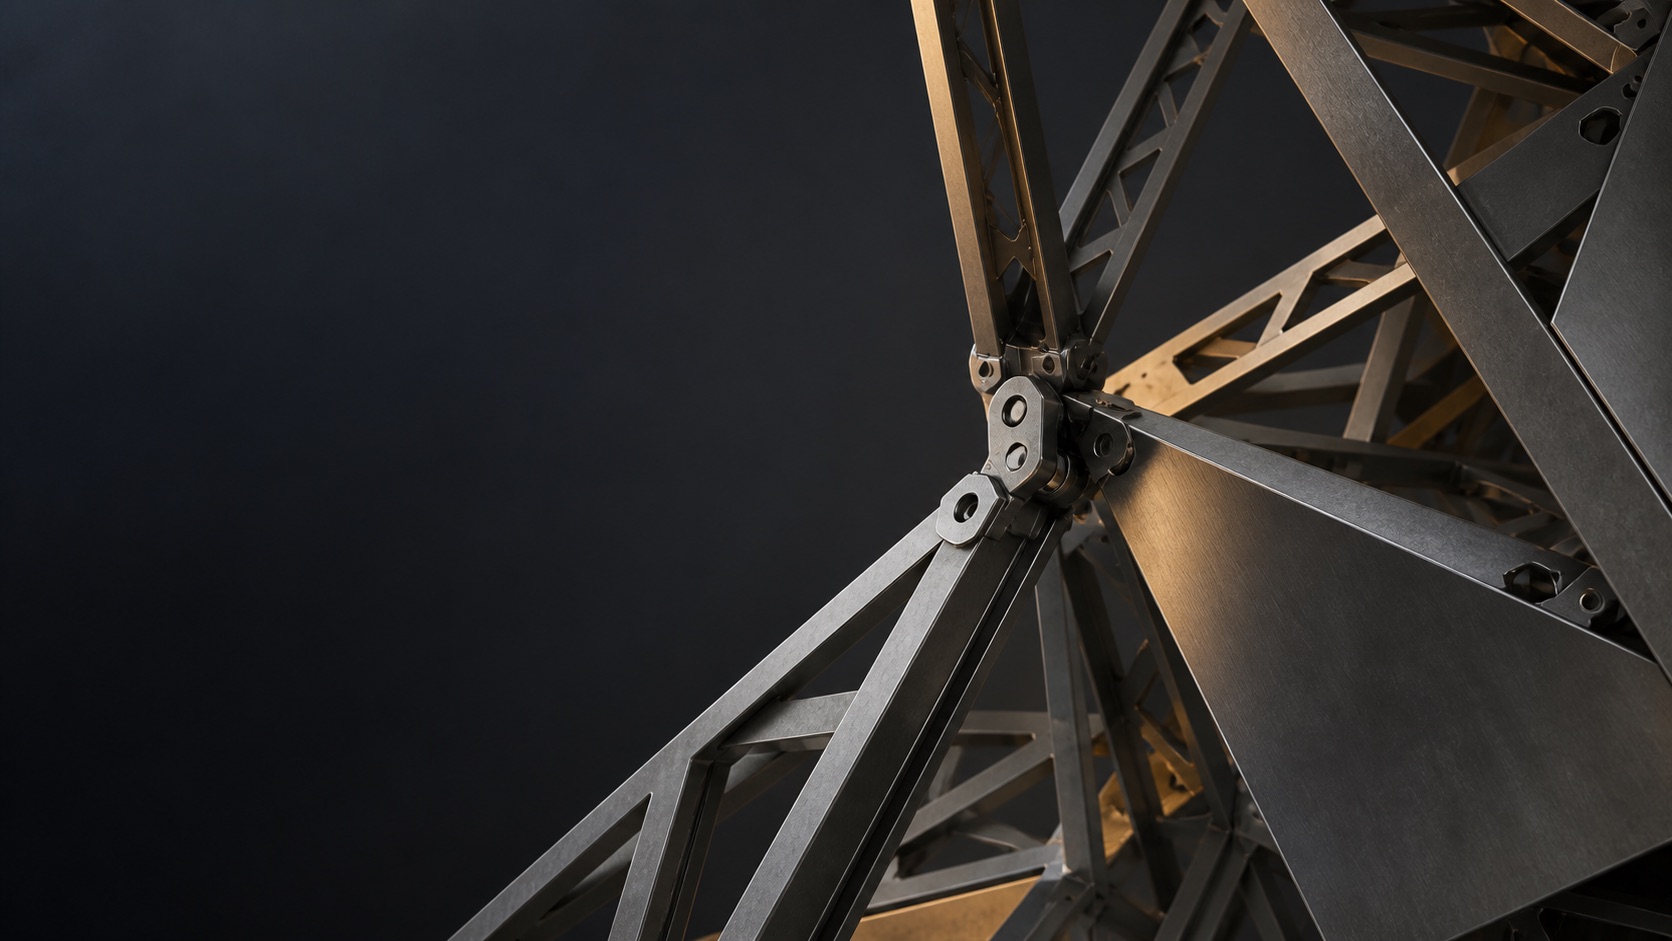
Transformable transportation system
A transformable transportation system based on the EXE-MTS architecture for mobility and operation in extreme and exo-environments.
Architecture profile
EXE-MTS family
The modular structural architecture forms a shared foundation. Its configurations extend it for the requirements of this operational field.
Modular structural architecture
A modular, transformable skeletal architecture for physical infrastructure, mobility, and adaptable structures in extreme and exo-environments.
Adaptable landing and support architecture
An adaptable architecture connecting landing gear, landing structure, and structural stabilisation across changing surface conditions.
Transformable mobility and propulsion architecture
A mobility architecture combining propulsive and wheel-based functions for different operating conditions.
Further building blocks contributing to the operational objective.
Resilient computing architecture
Self-Programmable Operating Resilient Environment: a self-programmable computing architecture for autonomous and swarm systems.
Intelligent communication architecture
Analog Geometric-Glyph Intelligence Communication: an intelligent communication architecture for autonomous and swarm systems in exo-environments.
Compact nuclear energy architecture
A nuclear energy system architecture combining ultra-fine reactivity control with extreme volumetric compactness.
Engineering and scientific foundation
These capabilities work as an integrated architecture connecting physical systems, control, energy, communication, and computing.
Models, optimisation, and mathematical foundations for coupled physical and intelligent systems.
Portable, distributed, and scalable computing and communication architectures.
Perception, state estimation, and control of dynamic systems under demanding conditions.
Transformable, modular, and load-bearing structures for changing tasks and environments.
Measurement systems and real-time interpretation of environmental, structural, and system states.
Electronic interfaces, power conversion, and robust hardware for integrated systems.
System architectures for controlled behaviour under faults, failures, and limited access.
Distributed decision and coordination architectures for cooperating systems.
Propulsion and mobility architectures that adapt to mission phase and environment.
Compact energy architectures for remote operations with limited supporting infrastructure.
Connected fields